🔬 Stellar SR6P7 — AUTOSAR Microcontroller Platform
AUTOSAR Classic — ETAS Tresos — BSW target & integration plan
Stellar SR6P7 — summary
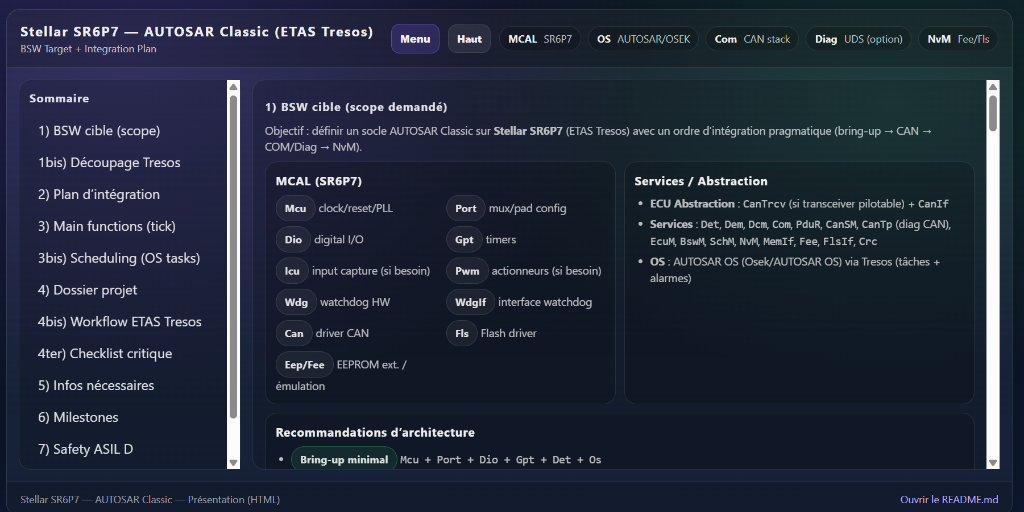
The Stellar SR6P7 — AUTOSAR Classic (ETAS Tresos) site is a technical platform designed to prepare and structure the development of the Basic Software (BSW) for an automotive ECU based on the Stellar SR6P7 microcontroller.
Goal: start from the microcontroller and its drivers, set up the OS, communications, diagnostics and memory, then prepare the full integration of the application software.
1. The SR6P7 MCAL foundation
The MCAL (Microcontroller Abstraction Layer) drivers: Mcu, Port, Dio, Gpt, Icu, Pwm, Wdg, Can, Fls, Eep/Fee — clocks, reset, PLL, I/O, timers, PWM, watchdog, CAN, Flash and non-volatile memory.
Chain: SR6P7 Hardware → MCAL → AUTOSAR BSW → Application.
2. AUTOSAR services
Above the MCAL: CanIf, CanTrcv, Det, Dem, Dcm, Com, PduR, CanSM, CanTp, EcuM, BswM, SchM, NvM, MemIf, Fee, FlsIf, Crc.
Covered functions: CAN communication → UDS diagnostics → ECU management → mode management → non-volatile memory → error supervision.
3. AUTOSAR OS and scheduling
Definition of tasks, alarms and scheduling mechanisms (AUTOSAR OS / OSEK) for deterministic ECU behavior: Initialization → Tasks → Cyclic execution → Events → Communication → Diagnostics → Supervision. The Main functions (tick) chapter defines periodic processing.
4. A progressive integration plan
Pragmatic order: Bring-up → OS → CAN → COM → Diagnostics → NvM. Each level is tested before moving on, which greatly eases defect hunting.
5. ETAS Tresos workflow
AUTOSAR configuration → ETAS Tresos → BSW generation → compilation → SR6P7 integration → testing. The site also acts as an AUTOSAR integration guide.
6. Project dossier, checklist and milestones
Managed like a real ECU project: Architecture → Configuration → Integration → Compilation → Bring-up → Testing → Validation, with a critical checklist and milestones.
7. ASIL D Safety
Integration of monitoring, diagnostics, watchdog, error handling and memory mechanisms required for functional safety — linked to ISO 26262 requirements.
From microcontroller to ECU
SR6P7 → MCAL → AUTOSAR OS → BSW → CAN/COM → Diagnostics → NvM → Safety → ECU Application: a complex AUTOSAR architecture turned into a concrete development plan, from bring-up to a structured, communicating and diagnosable software foundation.
Screenshot